What needed solving.
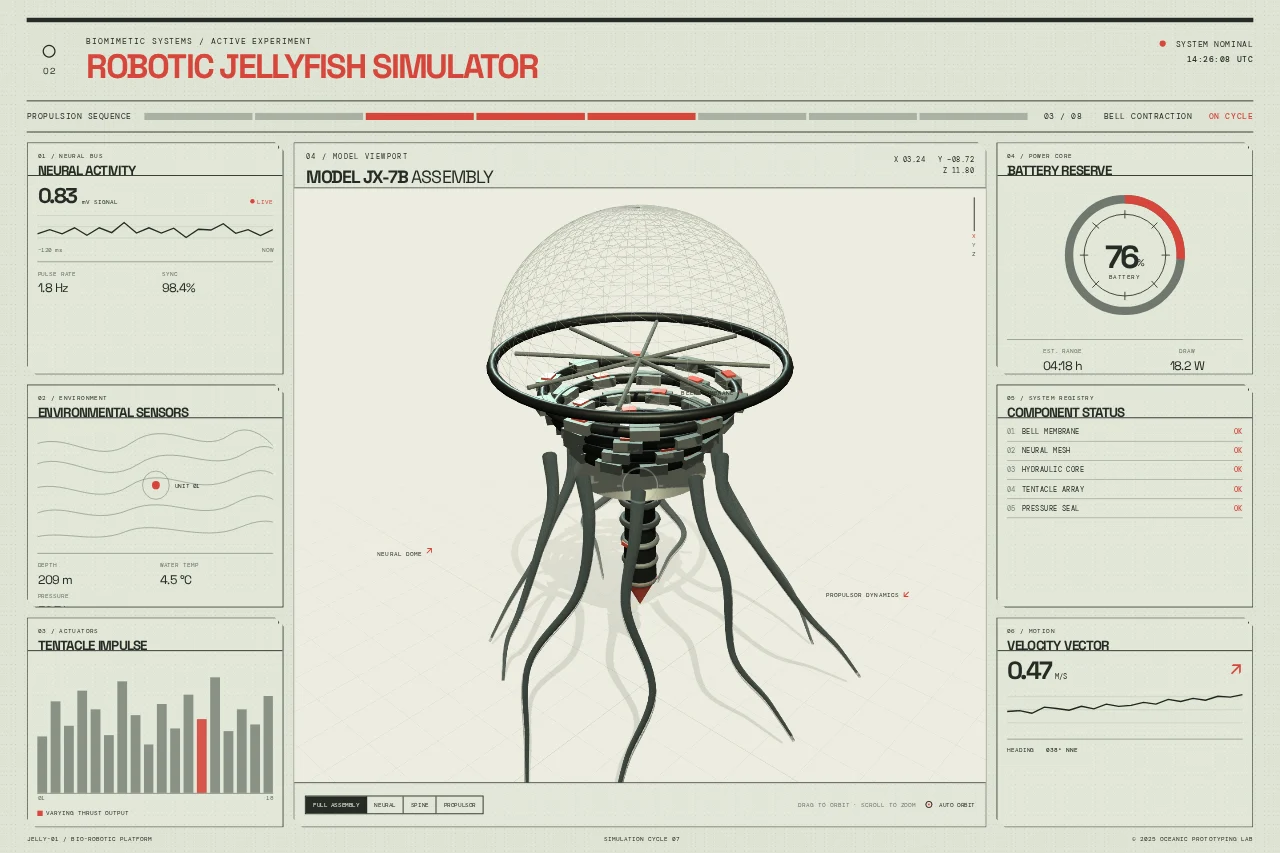
A complex bio-inspired robot concept is difficult to explain through a static render. The app provides a navigable assembly and focused subsystem views for the dome, neural package, spine, and propulsor, with visual cues for state and telemetry.
- 01Procedural geometry
- 02Subsystem state + camera
- 03Illustrative technical dashboard
Simplified from the implementation and project notes.
How it fits together.
The scene is authored procedurally in Three.js rather than imported from an engineering CAD assembly. Reusable geometry/material helpers build a pressure-dome visual, support structure, spine, and propulsion elements. A custom tapered-tube routine samples a Catmull-Rom curve, computes Frenet frames, and constructs indexed buffer geometry with normals and UVs.
React owns scene mode and interaction state; OrbitControls handles camera orbit and zoom. The dashboard UI exposes system isolation and animated state. The package uses Vite and TypeScript with React and Three.js; the README presents this as a concept, not a validated physical simulator.
The code also separates visual primitives from scene composition and React controls, so a subsystem mode can alter visibility/opacity without rebuilding the application around an imported asset. This makes the artifact useful as an interface and visual communication prototype while keeping its procedural model easy to inspect in source.
Building and checking it.
Start the Vite development server, orbit/zoom the assembly, and select a system to isolate it. The concept flow is visual inspection of a subsystem and its associated dashboard state; there is no documented physics or engineering-analysis pipeline.
The repository describes a dashboard concept and does not document validated kinematics, hydrodynamics, controls, sensor acquisition, or correspondence to a built robot. Telemetry should be presented as illustrative UI unless supported elsewhere; the model is visualization geometry, not engineering CAD.
Source notes
Based on repository code and project records reviewed on October 30, 2026. Historical checks are described as recorded, not rerun for this article. Screenshots, renders, and mockups are labeled individually.
robotic-jellyfish-simulator/README.mdrobotic-jellyfish-simulator/package.jsonrobotic-jellyfish-simulator/src/components/RobotScene.tsxrobotic-jellyfish-simulator/src/App.tsx